Embodied AI具身智能/Robot Navigation机器人导航/Manipulation机器人操作/NUS CLeAR LabNUS CLeAR 实验室

Jiaming Wang

Building robots that navigate the open world — without a map.

让机器人学会在没有地图的开放世界中导航。

PhD candidate in Computer Science at the National University of Singapore, advised by Harold Soh. In my “first life” I was a serial entrepreneur (one startup acquired) and spent a gap year at Oxford studying theology and philosophy. Now I build AI and robotics systems for spatial perception and mapping, long-term robot memory, autonomous navigation, and manipulation.新加坡国立大学计算机科学博士生,导师为 Harold Soh。“第一人生”里,我是一名连续创业者(其中一家公司被收购),并曾在牛津大学度过一年间隔年,研读神学与哲学。如今,我致力于构建面向空间感知与建图、机器人长期记忆、自主导航和操作的人工智能与机器人系统。

Jiaming Wang
ID编号JW-01 · ResearcherJW-01 · 研究员 Base所在地Singapore新加坡 Status状态● Recruiting students● 招收学生

01Awards & honors奖项与荣誉

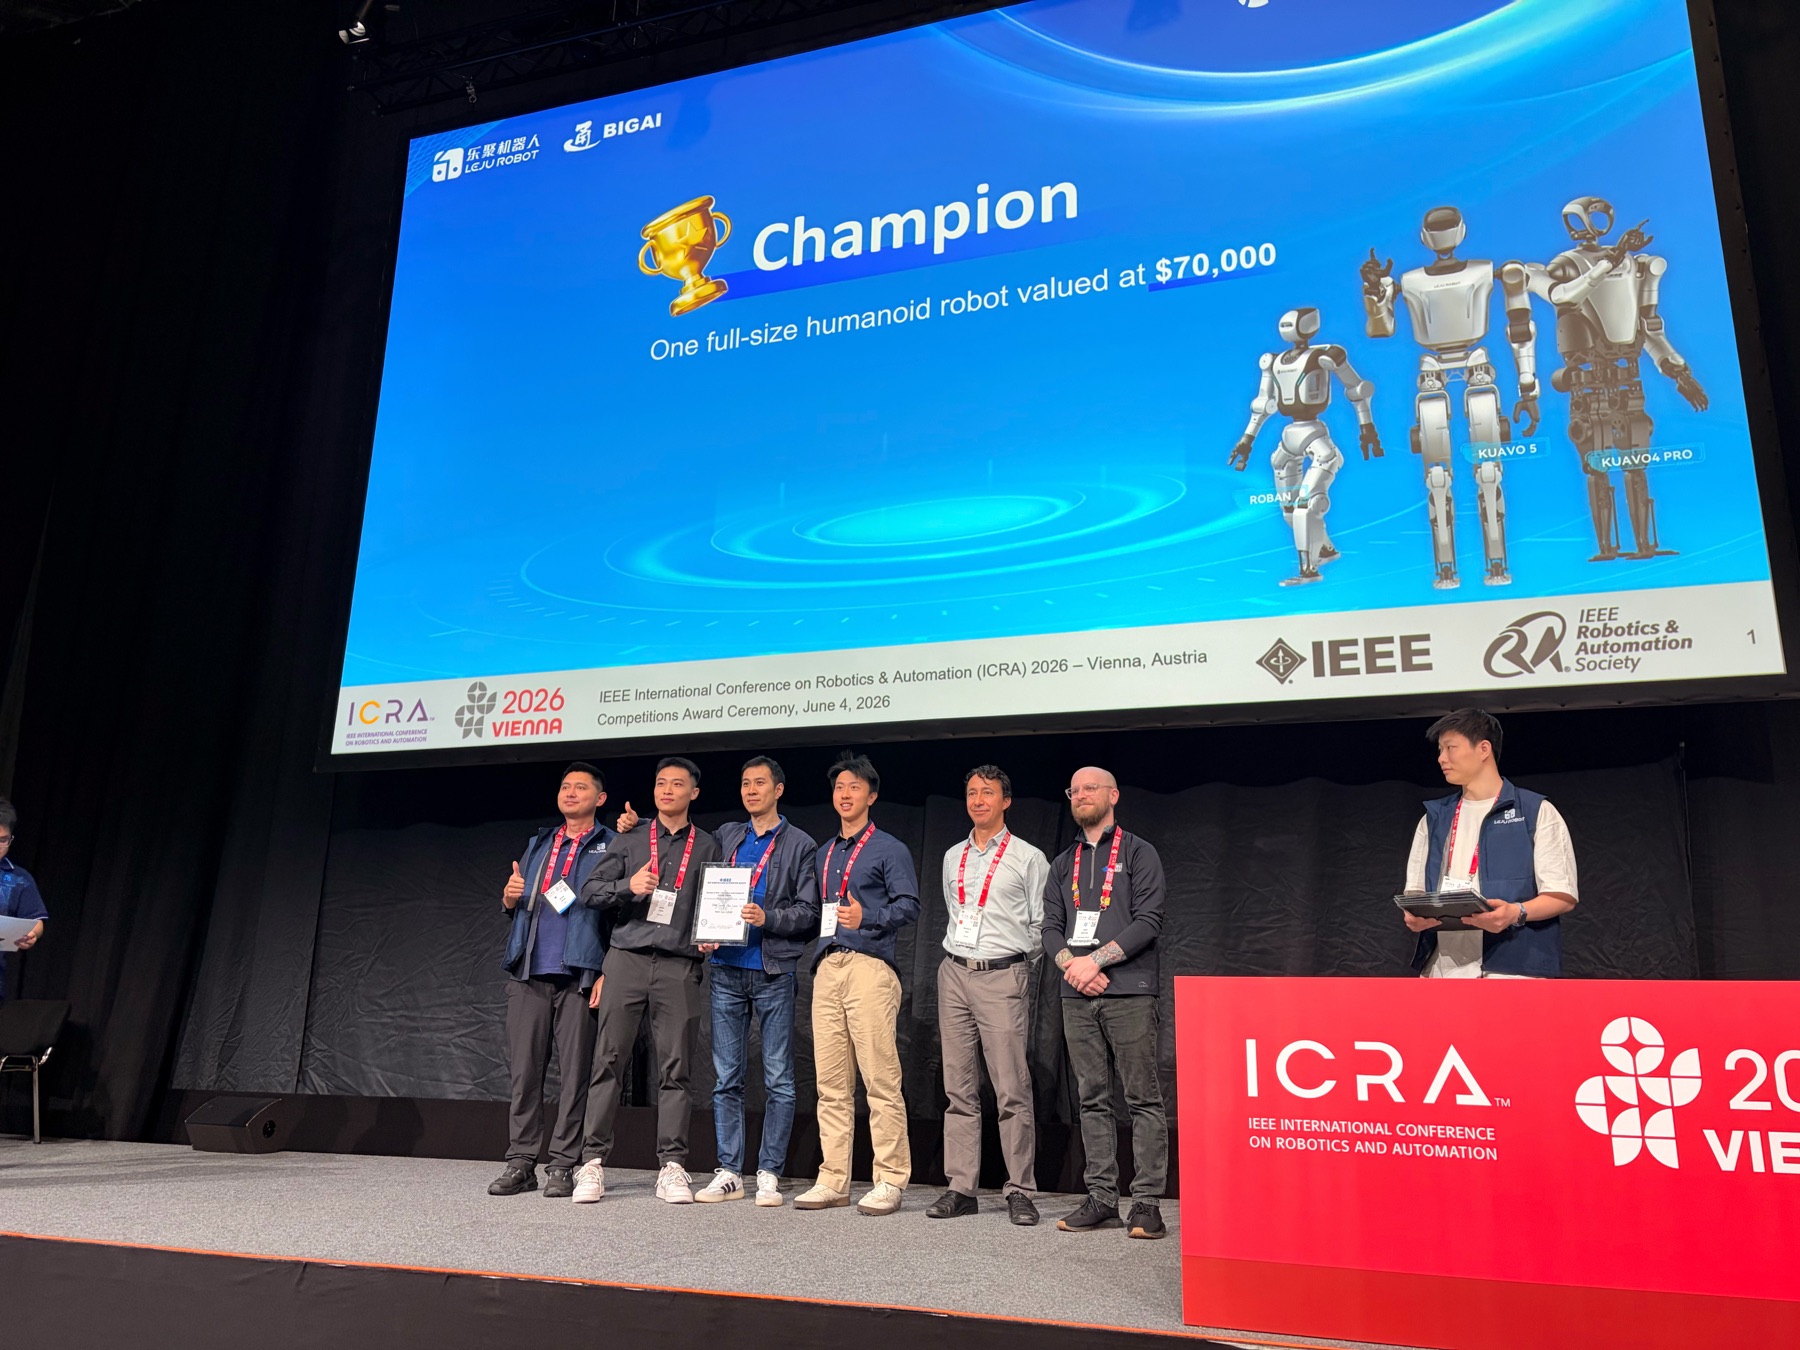
Team NUS-CLEAR on stage at the ICRA 2026 competitions award ceremony in Vienna Champion · 1st place冠军 · 第一名 2026
IEEE ICRA 2026 · ViennaIEEE ICRA 2026 · 维也纳

REAL-I: Real-world Embodied AI Learning ChallengeREAL-I:真实世界具身智能学习挑战赛

Won the inaugural challenge with an end-to-end robot learning and deployment system — through simulation, real-robot rounds, and an on-site physical-robot final. The win also brought our lab a $70,000 humanoid robot. Team NUS-CLEAR: Jiaming Wang, Jizhuo Chen, Diwen Liu; advisor Harold Soh.凭借端到端的机器人学习与部署系统,赢得首届挑战赛——历经仿真赛、真机轮次,以及现场实体机器人决赛。实验室也因此获得一台价值 7 万美元的人形机器人。NUS-CLEAR 团队:Jiaming Wang、Jizhuo Chen、Diwen Liu;指导教授 Harold Soh。
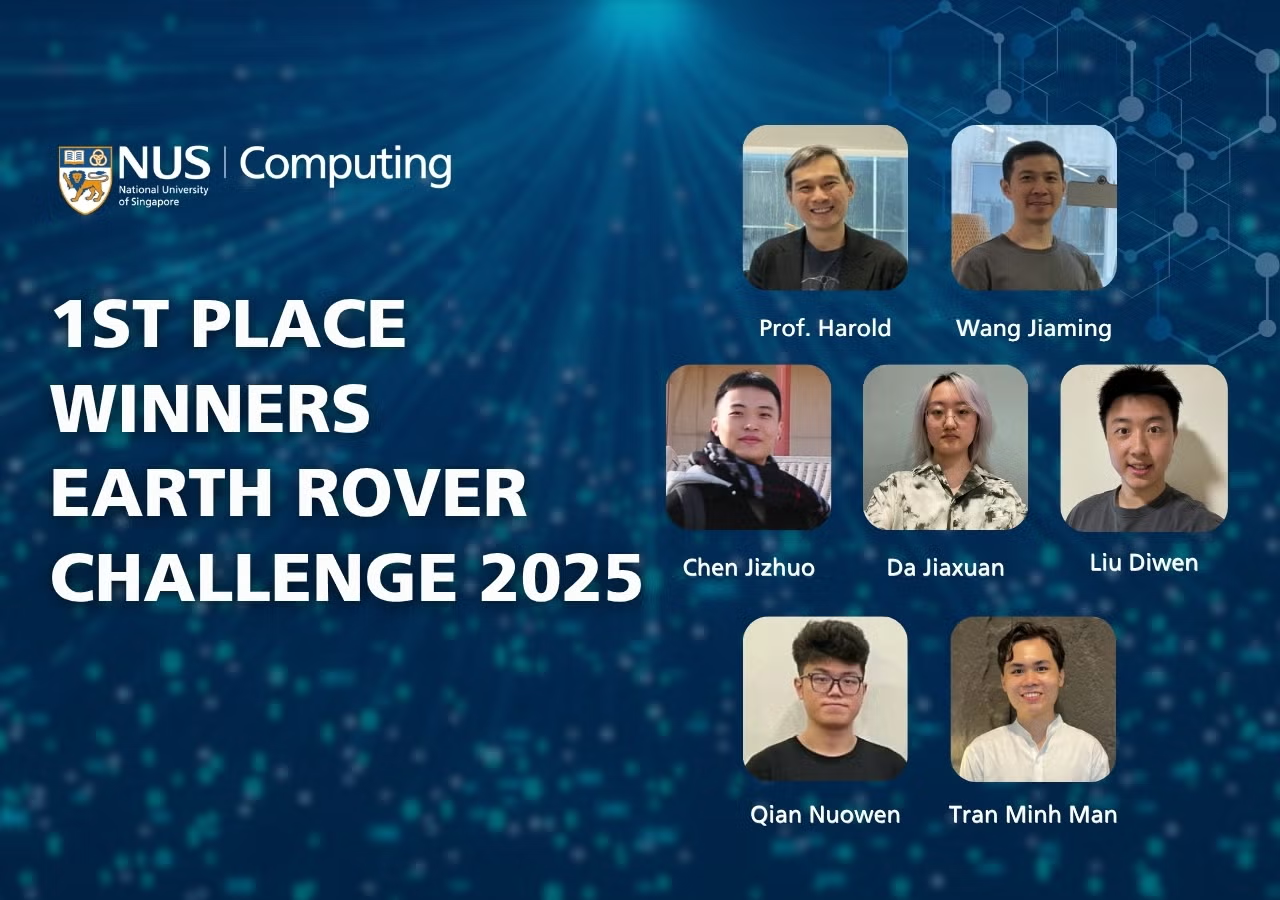
NUS Computing team — 1st place at the Earth Rover Challenge, ICRA 2025
7 countries · zero intervention7 个国家 · 零人工干预
Champion · 1st place冠军 · 第一名 2025
IEEE ICRA 2025 · AtlantaIEEE ICRA 2025 · 亚特兰大

Earth Rover Challenge

Led the GeNIE autonomous navigation system: low-cost rovers operated remotely across real-world environments in seven countries, navigating with just an RGB camera and noisy GPS.主导 GeNIE 自主导航系统的研发:低成本移动机器人在七个国家的真实环境中远程运行,仅依靠 RGB 相机与带噪声的 GPS 完成导航。

Forbes China 30 Under 30福布斯中国 30 Under 30
Recognized as co-founder of iCarsClub for technology innovation and entrepreneurship. Coverage因作为 iCarsClub 联合创始人在技术创新与创业方面的成就而获此殊荣。报道
2014

02Research focus研究方向

Robots that leave the lab. Two lines of work: environment representations that stay reliable across places, conditions and sensors, and robot policies that stay robust in the open world.走出实验室的机器人。两条研究主线:在不同场景、条件与传感器下依然可靠的环境表示,以及在开放世界中依然鲁棒的机器人策略。

LINE-01 · REPRESENTATION主线 01 · 环境表示

Open & Robust Environment Representation开放、鲁棒的环境表示

Representations that operate across environments, conditions, and sensing modalities: topological maps that relocalize after severe change, support object search, scale up with GPS, and even work underwater.能够跨环境、跨条件、跨传感模态工作的表示:在剧烈变化后仍能重定位的拓扑地图,支撑物体搜索,借助 GPS 扩展到大尺度场景,甚至可以在水下运行。

  • CROSSNeurIPS'26
    Open-world topological representation and localization.开放世界的拓扑表示与定位。
  • ECROMUnder review审稿中
    Extends CROSS toward long-term, open-vocabulary object search.将 CROSS 扩展到长期、开放词汇的物体搜索。
  • CROSS v2In progress进行中
    Stereo and monocular-inertial modes, frontend smoothing with local factor graphs, cloud support, and large-scale operation with GPS.支持双目与单目-惯性模式,基于局部因子图的前端平滑,云端支持,以及结合 GPS 的大尺度运行。
  • CROSS-UWIn progress进行中
    CROSS for underwater environments, where multi-session relocalization is particularly challenging.将 CROSS 扩展到水下环境——在那里,多次会话间的重定位尤为困难。
  • Semantic CROSS语义 CROSSExploring探索中
    Bringing richer semantic representations into the CROSS topological framework.在 CROSS 拓扑框架中引入更丰富的语义表示。
LINE-02 · POLICIES主线 02 · 机器人策略

Robust Robot Policies in the Open World开放世界中的鲁棒机器人策略

Policies that generalize beyond the lab: map-free navigation deployed in seven countries, championship-winning VLA post-training, social navigation learned from video, and foundation-model agents that reason, act, and improve.能够泛化到实验室之外的策略:已在七个国家部署的无地图导航,夺冠的 VLA 后训练,从视频中学到的社交导航,以及能够推理、行动并自我改进的基础模型智能体。

  • GeNIE Earth Rover · ICRA'25RA-L
    Generalizable in-the-wild navigation; won the ICRA 2025 Earth Rover Challenge.面向真实开放环境的可泛化导航系统;ICRA 2025 Earth Rover Challenge 冠军。
  • VLA post-trainingVLA 后训练 REAL-I · ICRA'26
    Won the ICRA 2026 REAL-I Challenge, through which our lab was also awarded a $70,000 humanoid robot.赢得 ICRA 2026 REAL-I 挑战赛,实验室也因此获得一台价值 7 万美元的人形机器人。
  • Social Navigation from Video从视频学习社交导航Under review审稿中
    Learning socially appropriate navigation behavior from large-scale video data.从大规模视频数据中学习符合社交规范的导航行为。
  • Agentic robotics智能体机器人Survey综述
    How foundation-model-based agents can reason, act, and improve in robotic systems.基于基础模型的智能体如何在机器人系统中推理、行动并自我改进。
  • Agentic world models智能体世界模型Exploring探索中
    A VLM constructs and reasons over a model of the world rather than directly predicting actions. Early results are very promising, for both manipulation and navigation.由 VLM 构建世界模型并在其上推理,而不是直接预测动作。初步实验结果非常可观,且同时适用于操作与导航。
TOG · IROS'25 WS GBPP · IROS'25 WS SCOPE · CoRL'26 Arena-Bench 2.0

03Mission log任务日志

  • Oct 20262026年10月SurveyNew survey: A Survey of Agentic Robotics: Toward Continual Self-Improvement. Read综述新综述 A Survey of Agentic Robotics: Toward Continual Self-Improvement 发布。阅读
  • Oct 20262026年10月PaperECROM, extending CROSS to long-term object search, is out on arXiv (under review). Project · arXiv论文将 CROSS 扩展到长期物体搜索的 ECROM 已发布于 arXiv(审稿中)。项目 · arXiv
  • Sep 20262026年9月PaperLearning Social Navigation from Internet Videos is out on arXiv (under review). Project · arXiv论文Learning Social Navigation from Internet Videos 已发布于 arXiv(审稿中)。项目 · arXiv
  • Sep 20262026年9月PaperCROSS accepted to NeurIPS 2026. Project · arXiv论文CROSS 被 NeurIPS 2026 录用。项目 · arXiv
  • Sep 20262026年9月ReportOur REAL-I challenge report, How to Better Train VLAs, is out on arXiv.报告我们的 REAL-I 挑战赛报告 How to Better Train VLAs 已发布于 arXiv。
  • 2026ServiceCo-organizing workshops at RSS 2026 (open-world navigation) and IROS 2026 (social robot navigation).服务共同组织 RSS 2026(开放世界导航)与 IROS 2026(社交机器人导航)workshop。
  • Jun 20262026年6月WinTeam NUS-CLEAR won 1st place at the REAL-I Challenge, ICRA 2026 in Vienna. The win also brought our lab a $70,000 humanoid robot.夺冠NUS-CLEAR 团队在维也纳举行的 ICRA 2026 上获得 REAL-I 挑战赛冠军,实验室也因此获得一台价值 7 万美元的人形机器人。
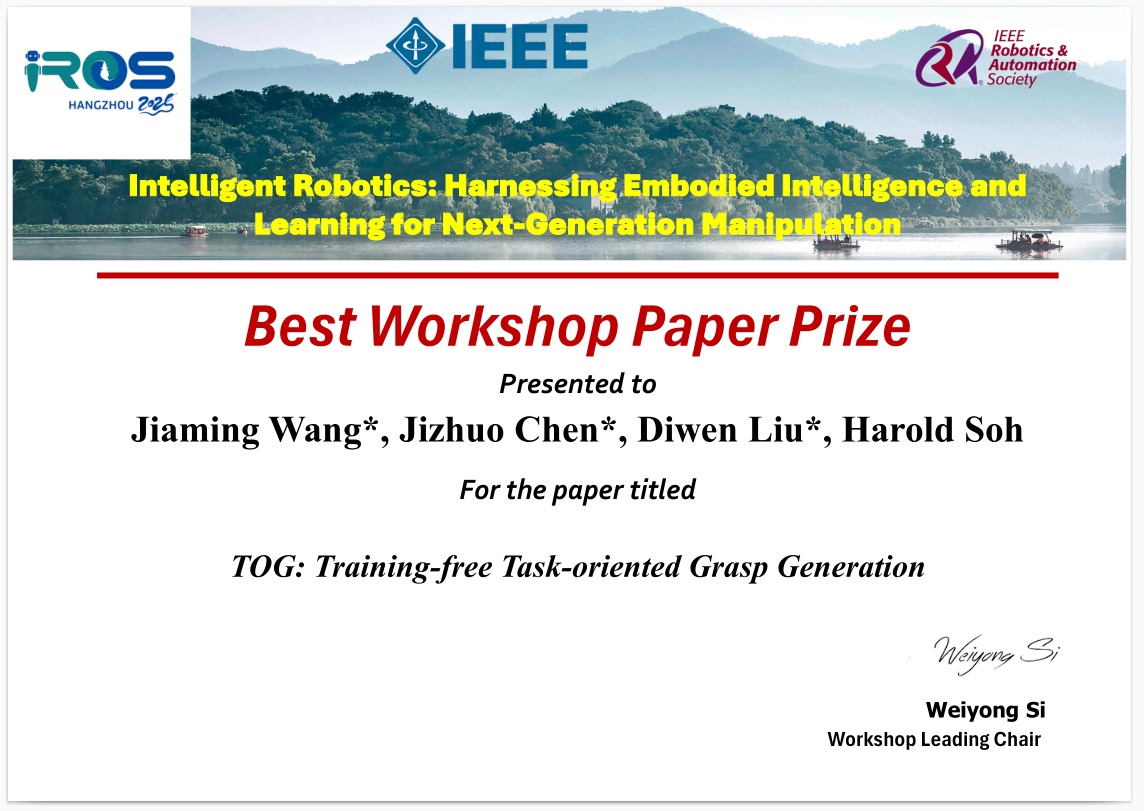
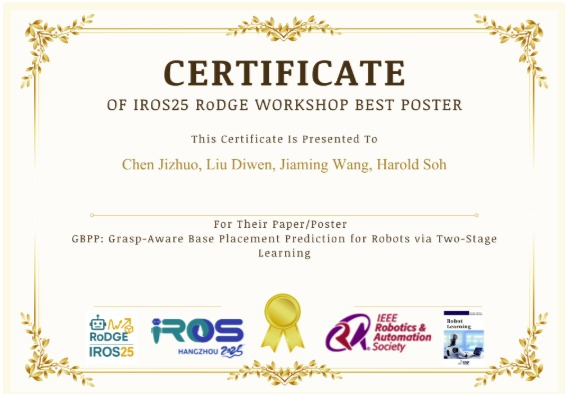
  • Oct 20252025年10月AwardTwo Best Paper Awards at IROS 2025 workshops (WIR-M and RoDGE).获奖在 IROS 2025 workshop(WIR-M 与 RoDGE)上获得两项最佳论文奖。
  • May 20252025年5月Win1st place at the Earth Rover Challenge, ICRA 2025 with the GeNIE navigation system.夺冠凭借 GeNIE 导航系统,在 ICRA 2025 的 Earth Rover Challenge 中获得冠军。

04Selected publications代表性论文

Survey 2026
A Survey of Agentic Robotics: Toward Continual Self-Improvement
Jiaming Wang, Yuhua Jiang, Zhengcheng Shen, Harold Soh
Preprint, 2026
Under review
Retrospective Open-Vocabulary Memory for Long-Term Object Search
Jiaming Wang, Zhiwei Xue, Jizhuo Chen, Shiqi Peng, Harold Soh
arXiv preprint (under review), 2026
Under review
Learning Social Navigation from Internet Videos in the Policy State Space
Jiaming Wang, Duc Thang Nguyen, Jizhuo Chen, Volodymyr Shcherbyna, Diwen Liu, Zhengcheng Shen, Harold Soh
arXiv preprint (under review), 2026
arXiv 2026
How to Better Train VLAs: Lessons Learned From the REAL-I Challenge at ICRA 2026
Jiaming Wang, Jizhuo Chen, Diwen Liu, Wang Song, Qiang Wang, Jie Ren, Chao Fu, Dingkun Zhu, Minchi Ruan, Hongtong Li, Yuhua Jiang, Zhiwei Xue, Yongping Pan, Harold Soh
arXiv preprint, 2026
Winner, REAL-I Challenge @ ICRA 2026ICRA 2026 REAL-I 挑战赛冠军
NeurIPS 2026
CROSS: Change-Robust Online Spatial-Semantic Topological Mapping
Jiaming Wang, Jizhuo Chen, Diwen Liu, Atharva Ghotavadekar, Jiaxuan Da, Linh Kästner, Harold Soh
Advances in Neural Information Processing Systems (NeurIPS), 2026
CoRL 2026
SCOPE: Control-Ready Uncertainty for Trajectory Diffusion
Zhiwei Xue, Kam Jia Yue, Jinhang Qiu, Yifeng Cheng, Ege Gursoy, Jiaming Wang, Vincent Bonnet, Harold Soh
Conference on Robot Learning (CoRL), 2026
ICRA 2026
TOPO-Bench: An Open-Source Topological Mapping Evaluation Framework with Quantifiable Perceptual Aliasing
Jiaming Wang, Jizhuo Chen, Diwen Liu, Jiaxuan Da, Jiamo Hu, Zhiwei Xue, Linh Kästner, Harold Soh
IEEE International Conference on Robotics and Automation (ICRA), 2026
arXiv
RA-L 2025
GeNIE: A Generalizable Navigation System for In-the-Wild Environments
Jiaming Wang, Diwen Liu, Jizhuo Chen, Jiaxuan Da, Nuowen Qian, Tram Minh Man, Harold Soh
IEEE Robotics and Automation Letters (RA-L), 2025
Winner, Earth Rover Challenge @ ICRA 2025ICRA 2025 Earth Rover Challenge 冠军
IROS 2025 WIR-M Workshop
Training-Free Task-Oriented Grasp Generation
Jiaming Wang, Diwen Liu, Jizhuo Chen, Harold Soh
WIR-M Workshop, IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
Best Workshop Paper PrizeWorkshop 最佳论文奖
arXiv
IROS 2025 RoDGE Workshop
GBPP: Grasp-Aware Base Placement Prediction for Robots via Two-Stage Learning
Jizhuo Chen, Diwen Liu, Jiaming Wang, Harold Soh
RoDGE Workshop, IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
Best Paper Award最佳论文奖
arXiv
ICRA 2024
Probable Object Location (POLo) Score Estimation for Efficient Object Goal Navigation
Jiaming Wang, Harold Soh
IEEE International Conference on Robotics and Automation (ICRA), 2024
arXiv

All publications全部论文

05Workshop organizationWorkshop 组织

06Teaching教学

CS5242
Neural Networks and Deep Learning神经网络与深度学习
Teaching Assistant · 2026助教 · 2026
CS5284
Graph Machine Learning图机器学习
Teaching Assistant · 2024, 2025助教 · 2024、2025

07Join the mission加入我们

Looking for student researchers.正在招募学生研究员。

I'm actively looking for motivated students to work on cutting-edge problems in robot navigation and embodied AI in general. My research has won two international robotics challenges at ICRA and two Best Paper Awards at IROS workshops. I approach research with an entrepreneurial mindset—prioritizing rapid prototyping, real-world deployment, and practical impact.我正在积极招募有热情的学生,一起攻克机器人导航乃至具身智能领域的前沿问题。我的研究曾赢得两项 ICRA 国际机器人挑战赛冠军和两项 IROS workshop 最佳论文奖。我以创业者的思维做研究——强调快速原型、真实世界部署与实际影响力。

My past students have gone on to excellent opportunities, including PhD offers from CUHK and NUS, as well as collaborations with leading research groups. I emphasize hands-on mentorship, giving students real ownership of projects and fostering both technical depth and independent thinking.我指导过的学生已获得出色的发展机会,包括香港中文大学(CUHK)和新加坡国立大学(NUS)的博士录取,以及与顶尖研究团队的合作。我注重手把手的指导,让学生真正主导自己的项目,同时培养技术深度与独立思考能力。

Python / C++ROS 2Real robots真机Ownership担当Curiosity好奇心